Gimbal
Overview
I worked on a gimbal over the summer of 2026, where I designed, coded, and fabricated all parts required. I made this for the purpose of stabilizing a camera on all 3 axes.
What I built
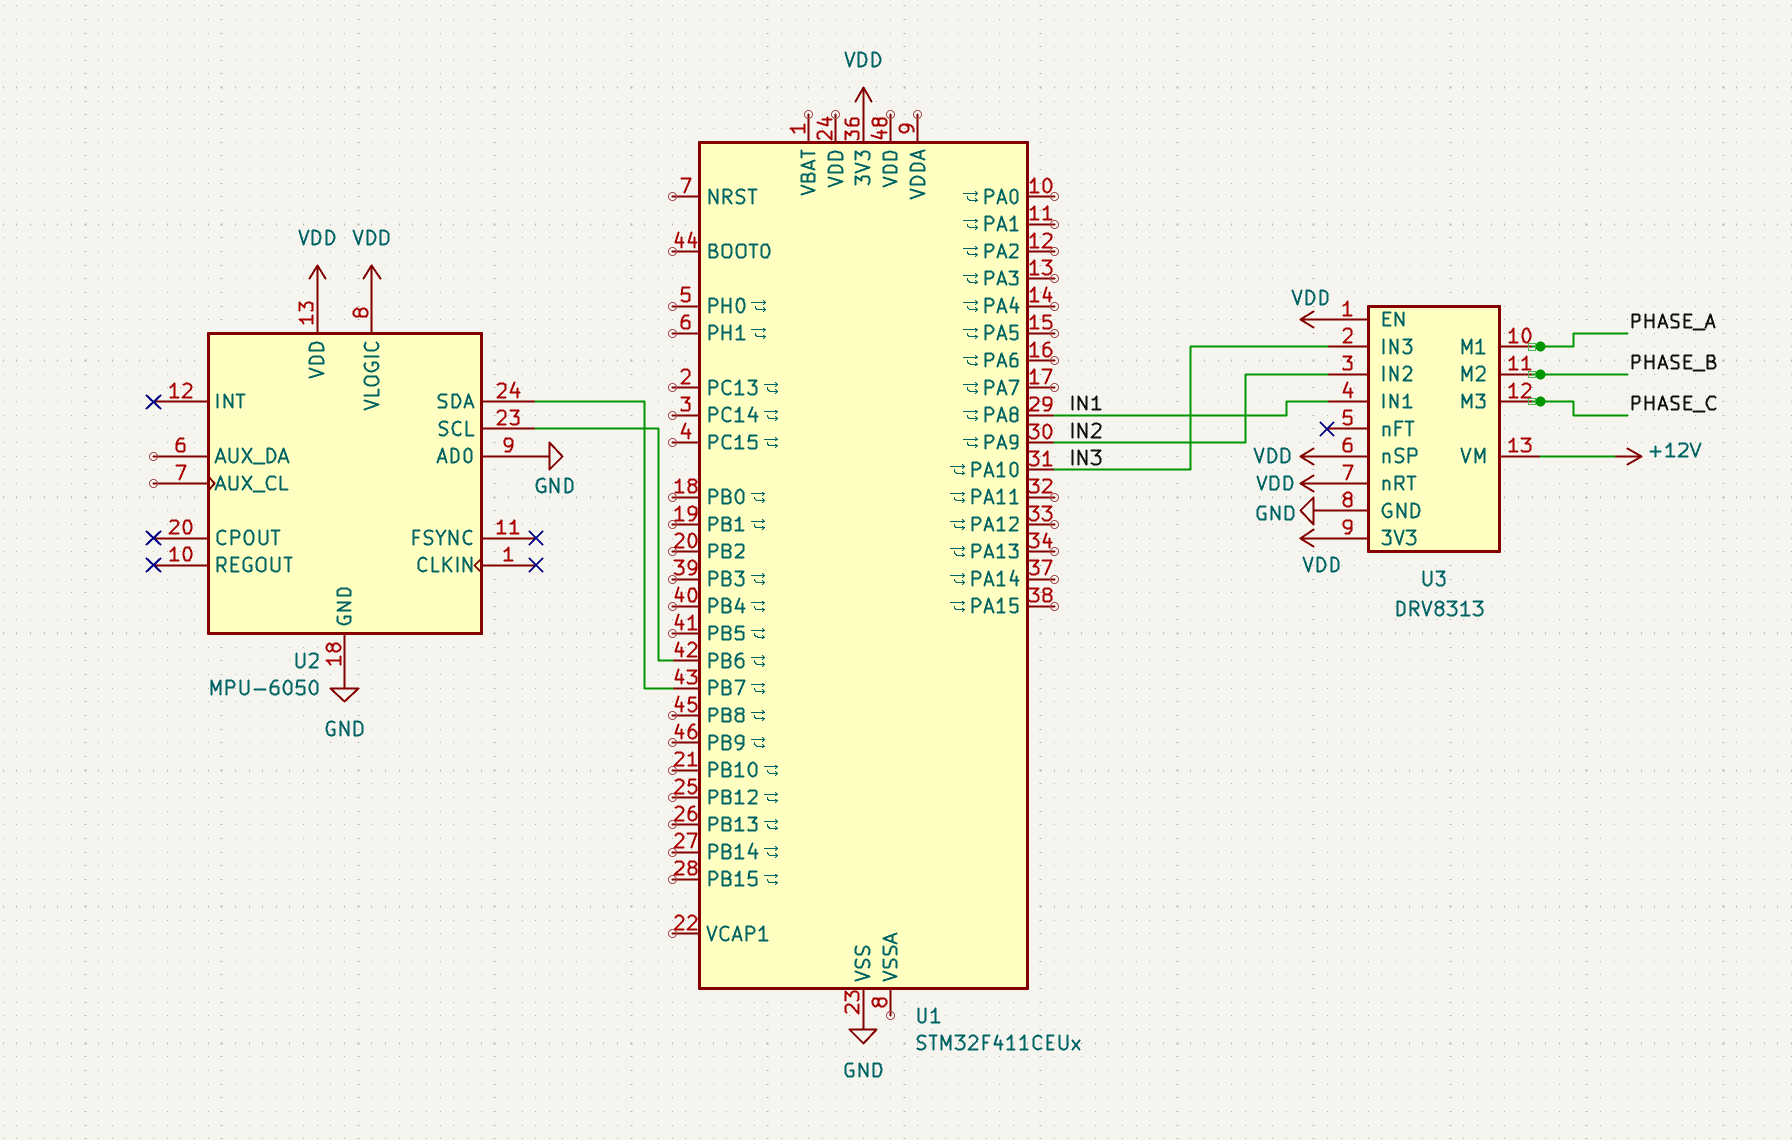
- I drew out the wiring diagram in KiCAD, and integrated an STM32F411 microcontroller with a AS5048A encoder and MPU6050 inertial measurement unit to keep the platform stable.
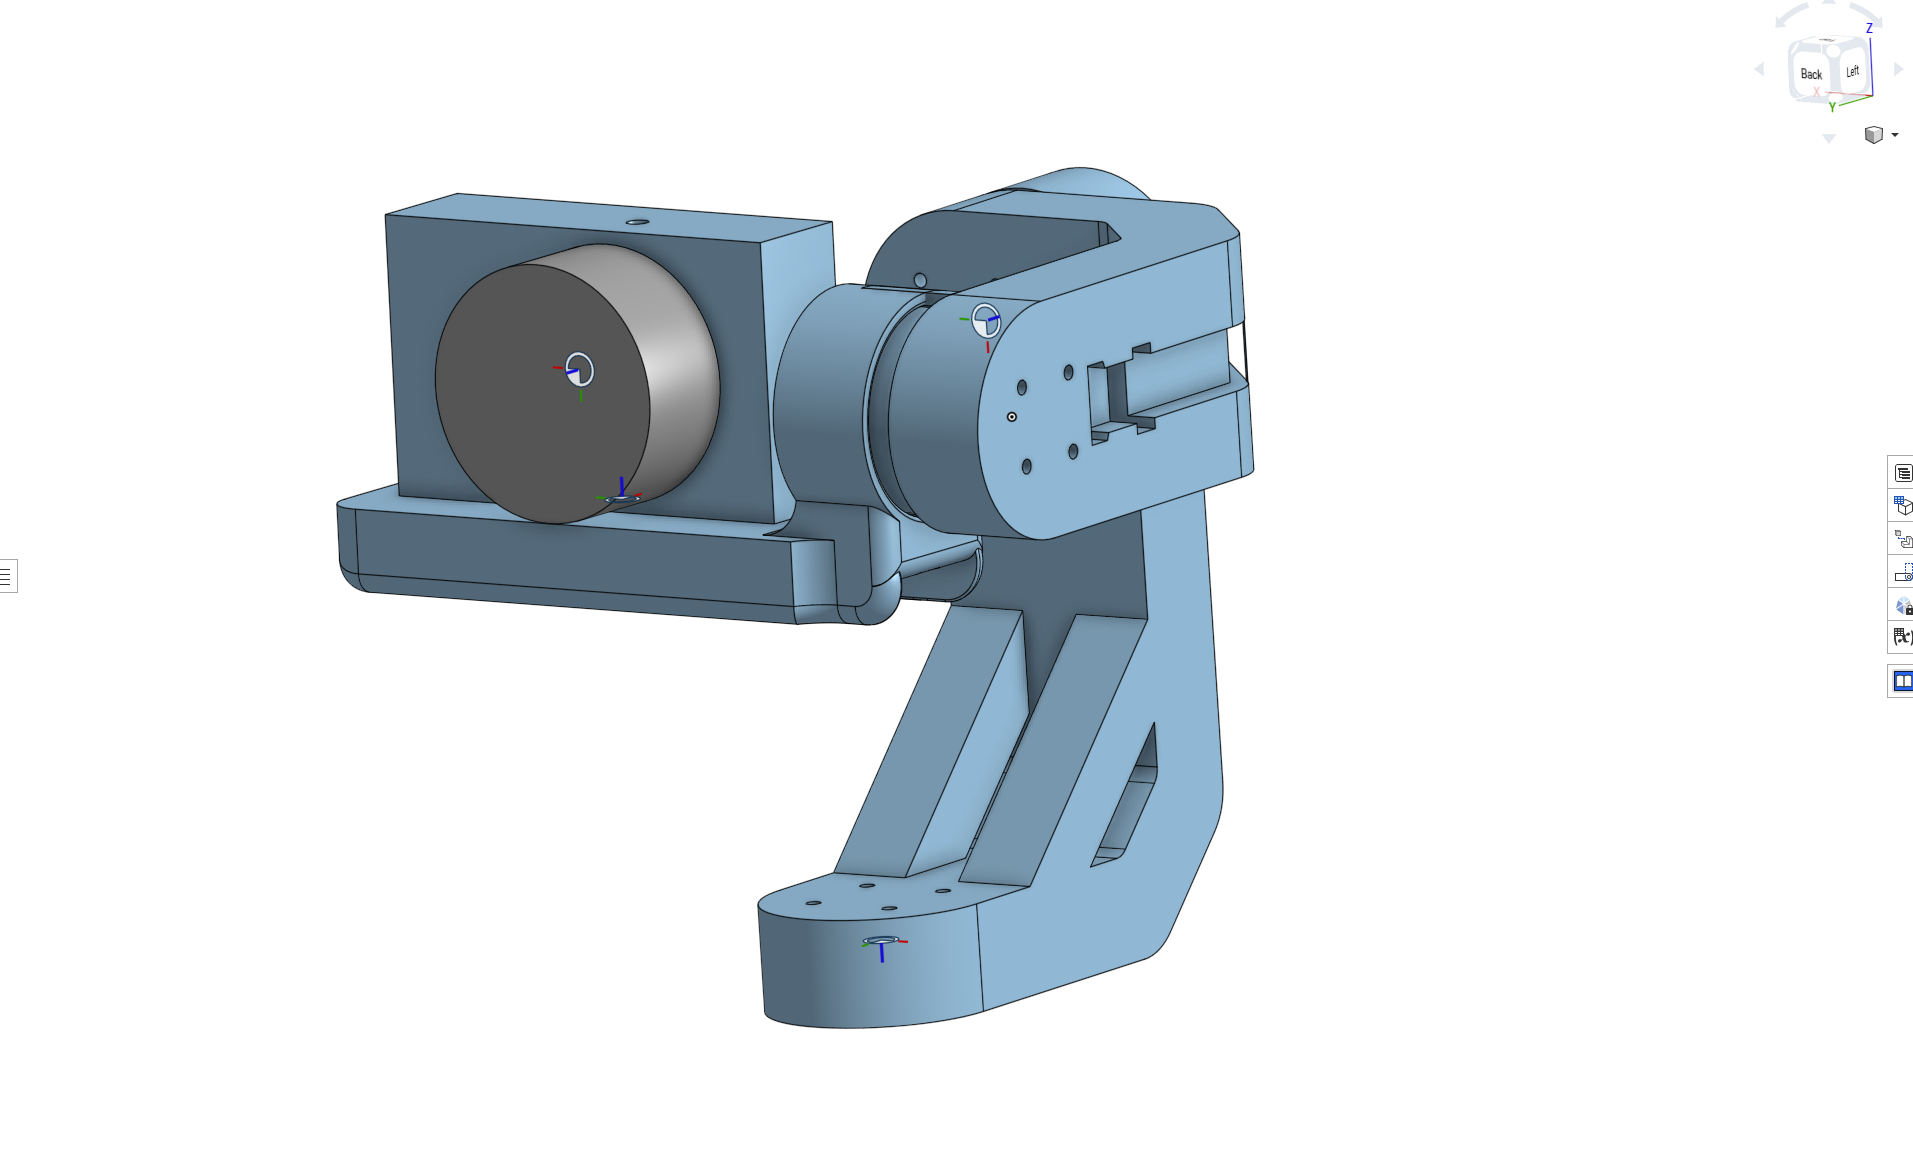
- I designed the structural housing of the gimbal using Onshape, and 3D printed it using my Bambu Lab A1 Mini printer.
- By using SimpleFOC, I was able to finely control the movement of the motor. I implemented the cascaded PID in C++.
- You can see the GitHub repository here.
Result
I was able to successfully attenuate the tilt axis and stabilized it. This is still a work in progress.